Rough automatic draft, low quality: expect mistakes and awkward wording. It will be replaced by a better translation. Original →
16
Field of softness of a spherical-homogeneous body
I. I. Ogievetsky
Newton’s law of universal gravitation equally determines the fall of an apple to the ground, the movement of the Moon around the Earth, and the orbits of the planets. It is based on the fact that the tension force between material points with masses and , located at a distance from each other, is equal to
(1)
where is the gravitational constant (in the SI system). But the Earth, Moon and other real bodies are not exact, they have finite sizes. How to determine the tension force between stranded bodies?
The solution to this problem led Newton to the creation of the most important branch of mathematics - integral calculus. To find the force of constriction of a material point to a conjugate body, you should mentally divide this body into small (in the limit - infinitesimal) parts, calculate the contribution to the constriction force from each of these parts using formula (1) and then add (interpret) these contributions. Celestial bodies can be approximately considered spherical-homogeneous, that is, such that at any given point their density is entirely determined by the distance of this point from the center of the body. Newton discovered a remarkable fact:
(2)
where is the surface mass. In other words, the tensile force outside the spherical surface is the same as if the entire mass of the surface were concentrated at its center. This immediately implies a similar statement for a spherical homogeneous body.
*) This property is often used as very important, without proof. Use it in some articles «Kvant». Therefore, it is very useful to understand how it proves.
18
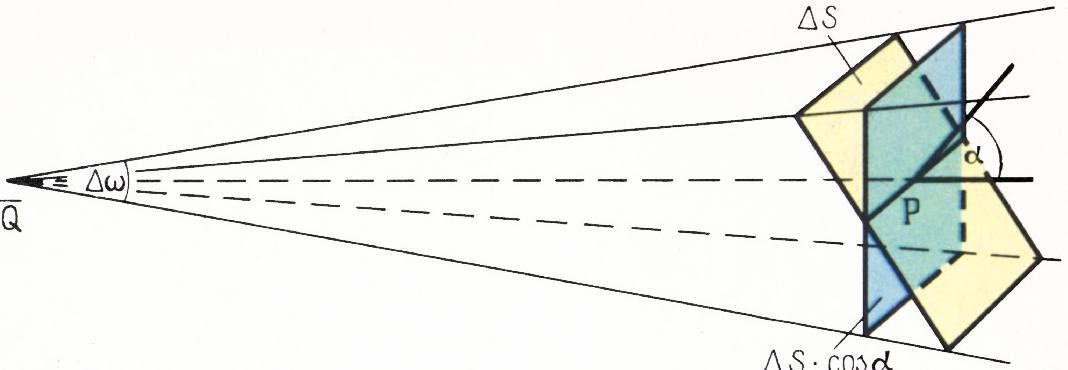
Fig. 3.
Let us now use inversion and replace in (6) with according to (4):
(7)
where the values are entered
Let’s make an important observation. Note that is also the angle between the normal (radius ) to the surface element and the direction , and cosa is set for any point .
It is therefore easy to verify that is the solid angle at which the surface element is visible from point .
If you introduce a cone with the vertex at point and a running contour is formed, then the solid angle at the vertex of this cone will be (Fig. 3).
Numerically, the angle is equal to the area that this cone cuts out from a sphere of unit radius with center at point .
*) This is where the inversion operation is essential. With its help, we introduced the distance into the denominator (6) instead of the distance , thanks to which the solid angle appeared in the formula.
Full acceptance of all surfaces :
(8)
since is the total solid angle at which the entire sphere is visible from the interior point , and is the total mass of the spherical surface. Thus, Statement 1 is proven.
Let us now consider a material point of mass inside a hollow spherical surface. Again from the messages of symmetry it is very clear that the force generated by the spherical surface as a whole can only be directed along the line .
Therefore, we need to add the components of the force from the elements of the sphere , equal to
(9)
if we use it again, we take it from inversion and replace with according to correspondence (4).
Calculation of the sphere into two parts and by a plane passing through the point perpendicular to the line